hero lab · 2025
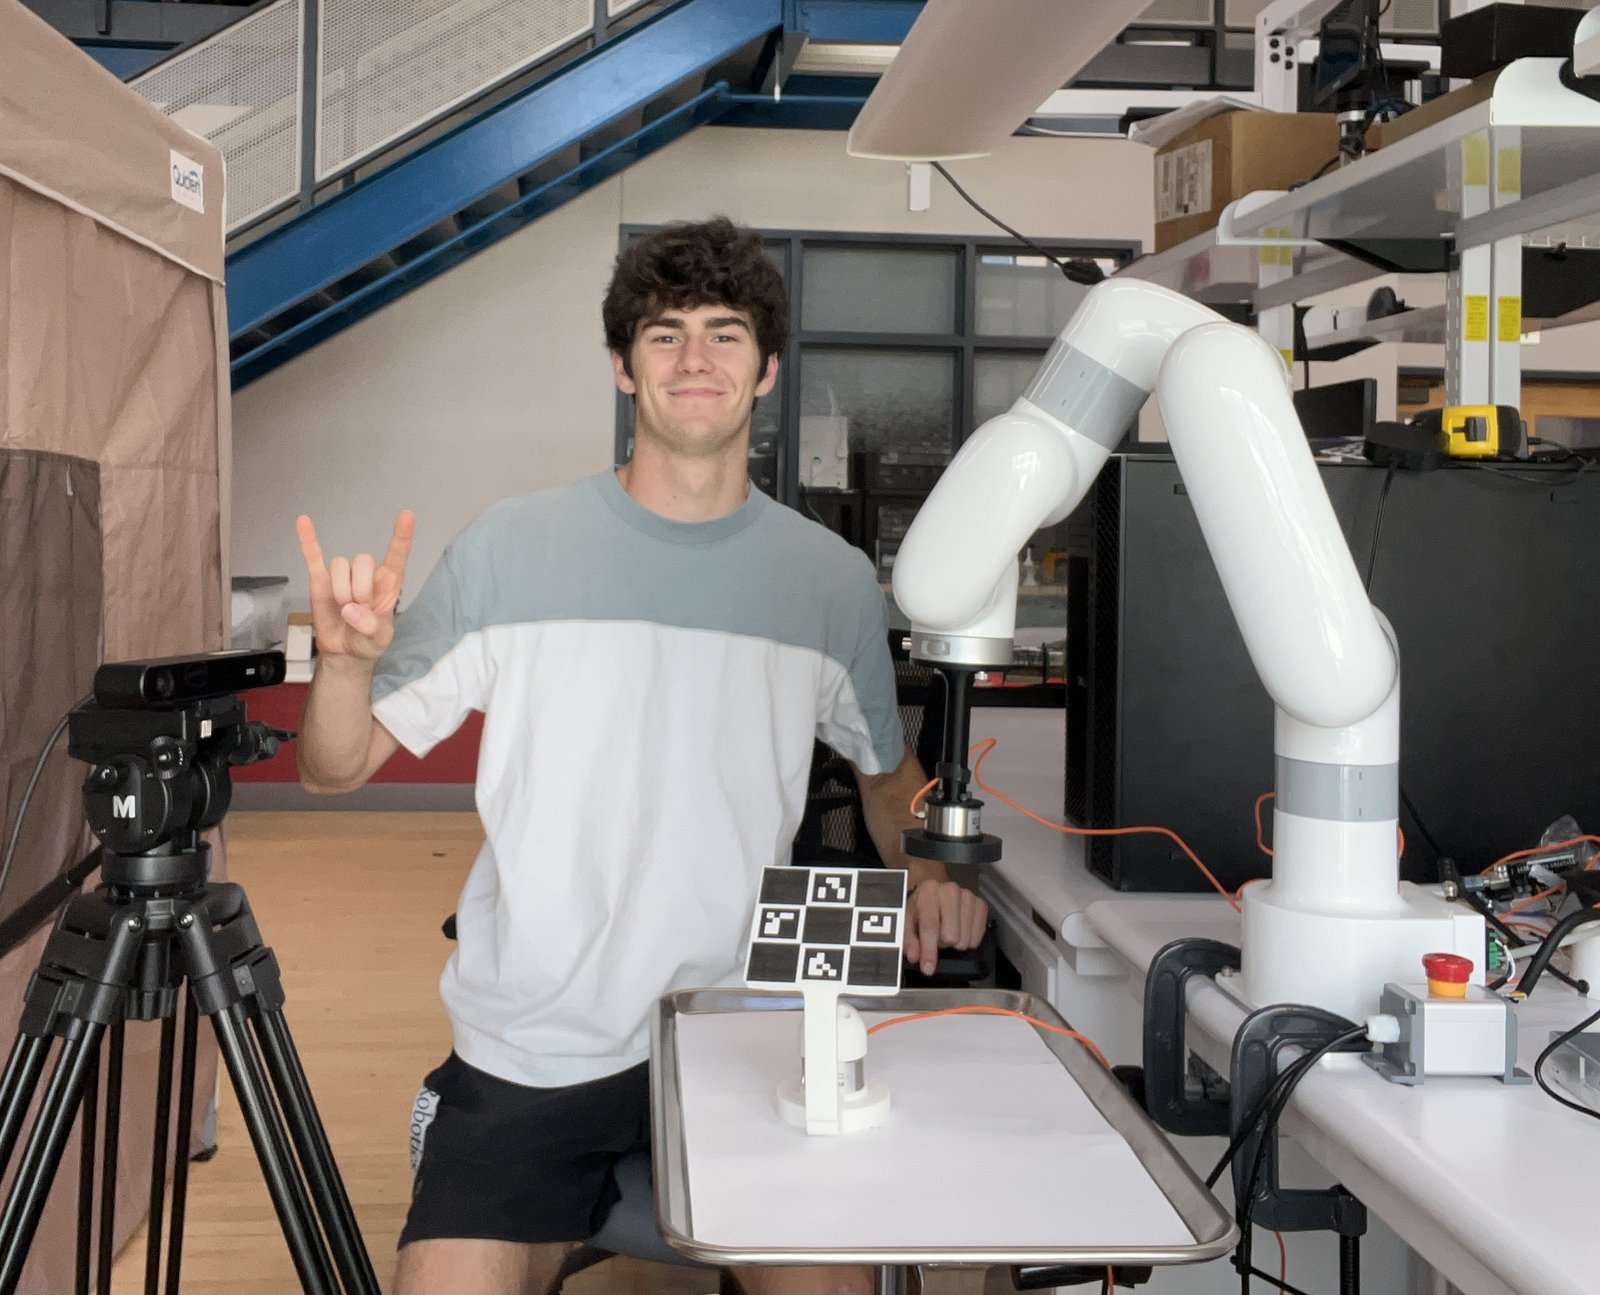
Surgical Cleaning Robot
Autonomous operating room cleaning robotic arm developed at HERO Lab, Texas Robotics, designed for sterile environments and medical tool sanitation.
I'm a UT Electrical & Computer Engineering student passionate about Embedded Systems, Firmware, and Computer Architecture

“Leadership is about making others better, and ensuring that impact lasts in your absence.”
— Coach Cabrera
I'm an Electrical & Computer Engineering student at UT Austin in the Inaugural Texas Robotics Honors Cohort focused on computer architecture, embedded systems, and on-device intelligence.
I'm especially passionate about nature inspired robotics and perpetual autonomy. I believe deeply that the most elegant solutions to modern problems are often deceptively effortless.
Currently I am conducting research at Texas Robotics and the Human Enabled Robotics Lab (HERO Lab). I've built out autonomous operating room cleaning systems, published open source robotics education devices, and designed rehabilitation wearables providing haptic feedback based on muscle activity. I'm always looking for exciting opportunities to help learn and grow.
Outside of engineering, I enjoy building robots (oops thats engineering again), rock climbing, backpacking, soccer, game development, and watching the Longhorns.
Autonomous operating room cleaning robotic arm developed at HERO Lab, Texas Robotics, designed for sterile environments and medical tool sanitation.
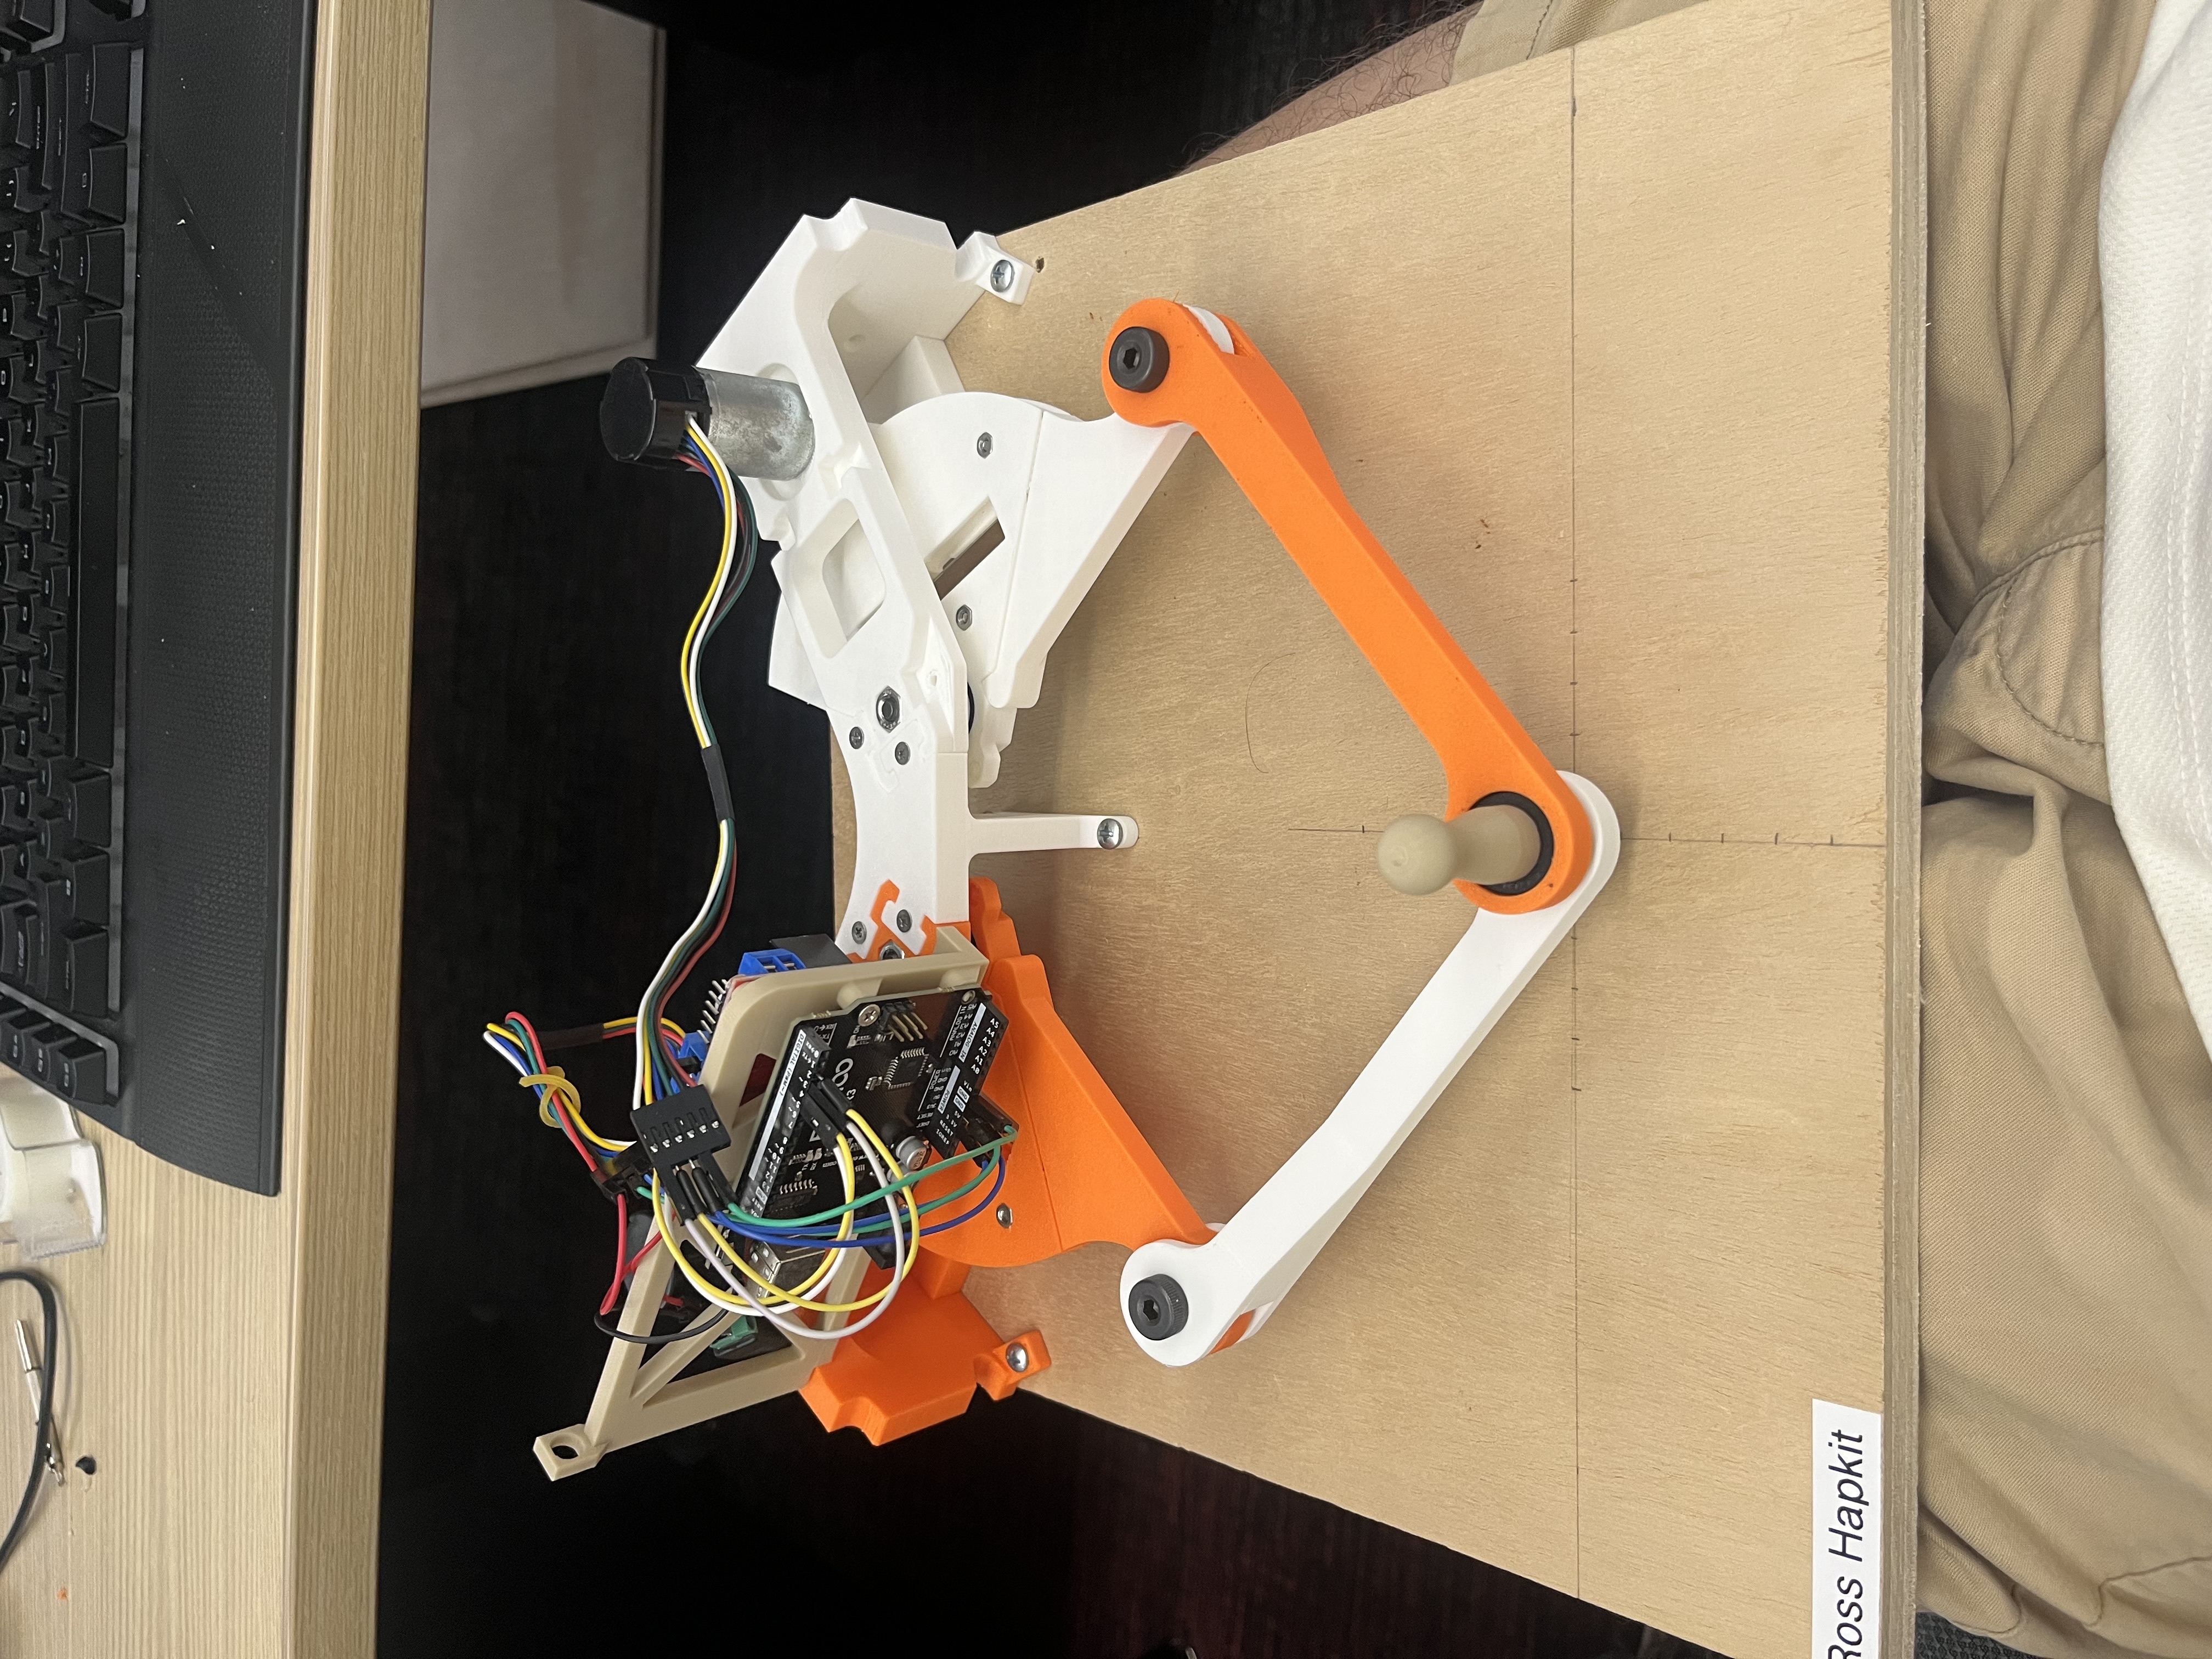
2-DOF educational haptic device demonstrating force feedback and virtual physics. Features custom serial communication protocol and 100Hz real-time control loop.
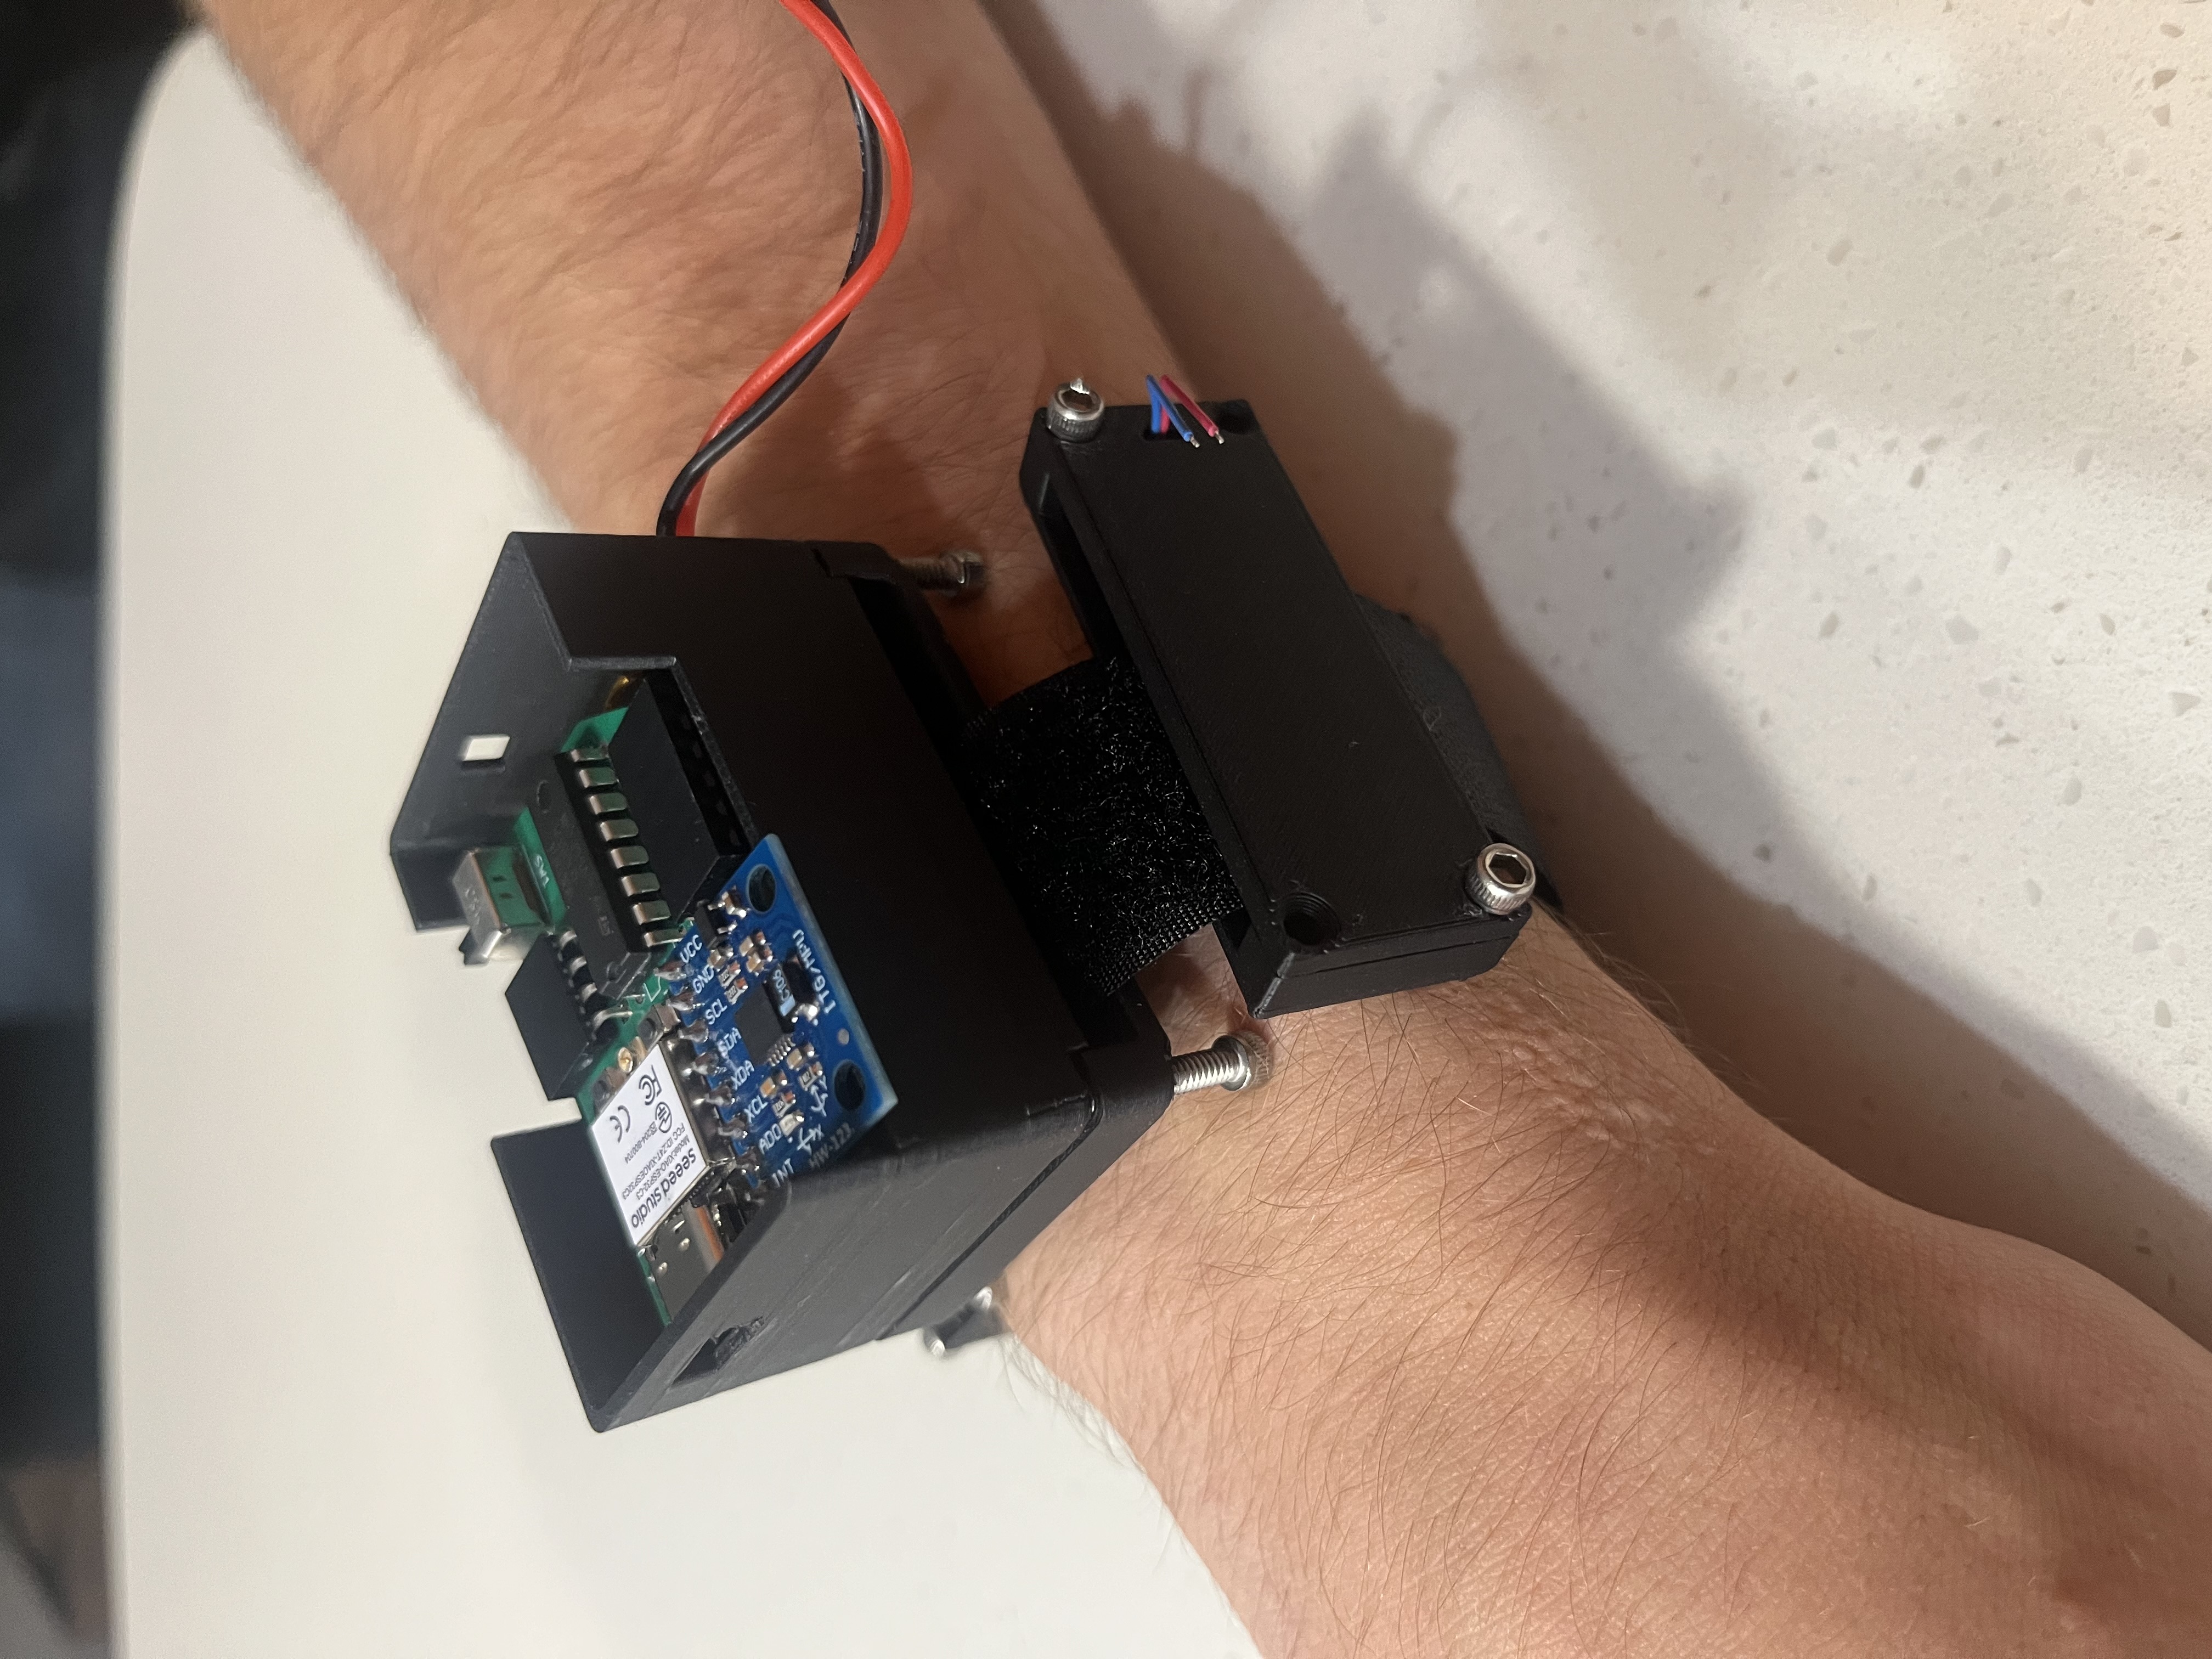
Low-cost wearable band system providing directional haptic feedback for large motor skill learning. Built with custom PCB and sub-millisecond wireless communication.